About
I am a Ph.D. student in Mechanical and Aerospace Engineering at UC San Diego, advised by Prof. Sylvia Herbert in the Safe Autonomous Systems Lab.
I am interested in developing control and learning methods that combine mathematical rigor with broad applicability to robotic systems, drawing on optimal control and reinforcement learning. My research has focused on the connections between Hamilton–Jacobi reachability and control barrier functions, and on ensuring safety and stabilization for nonlinear systems under uncertainty.
My recent work develops diffusion and flow policies for safe reinforcement learning.
I’m seeking research internship opportunities for Summer 2027 in the U.S. Please feel free to get in touch.
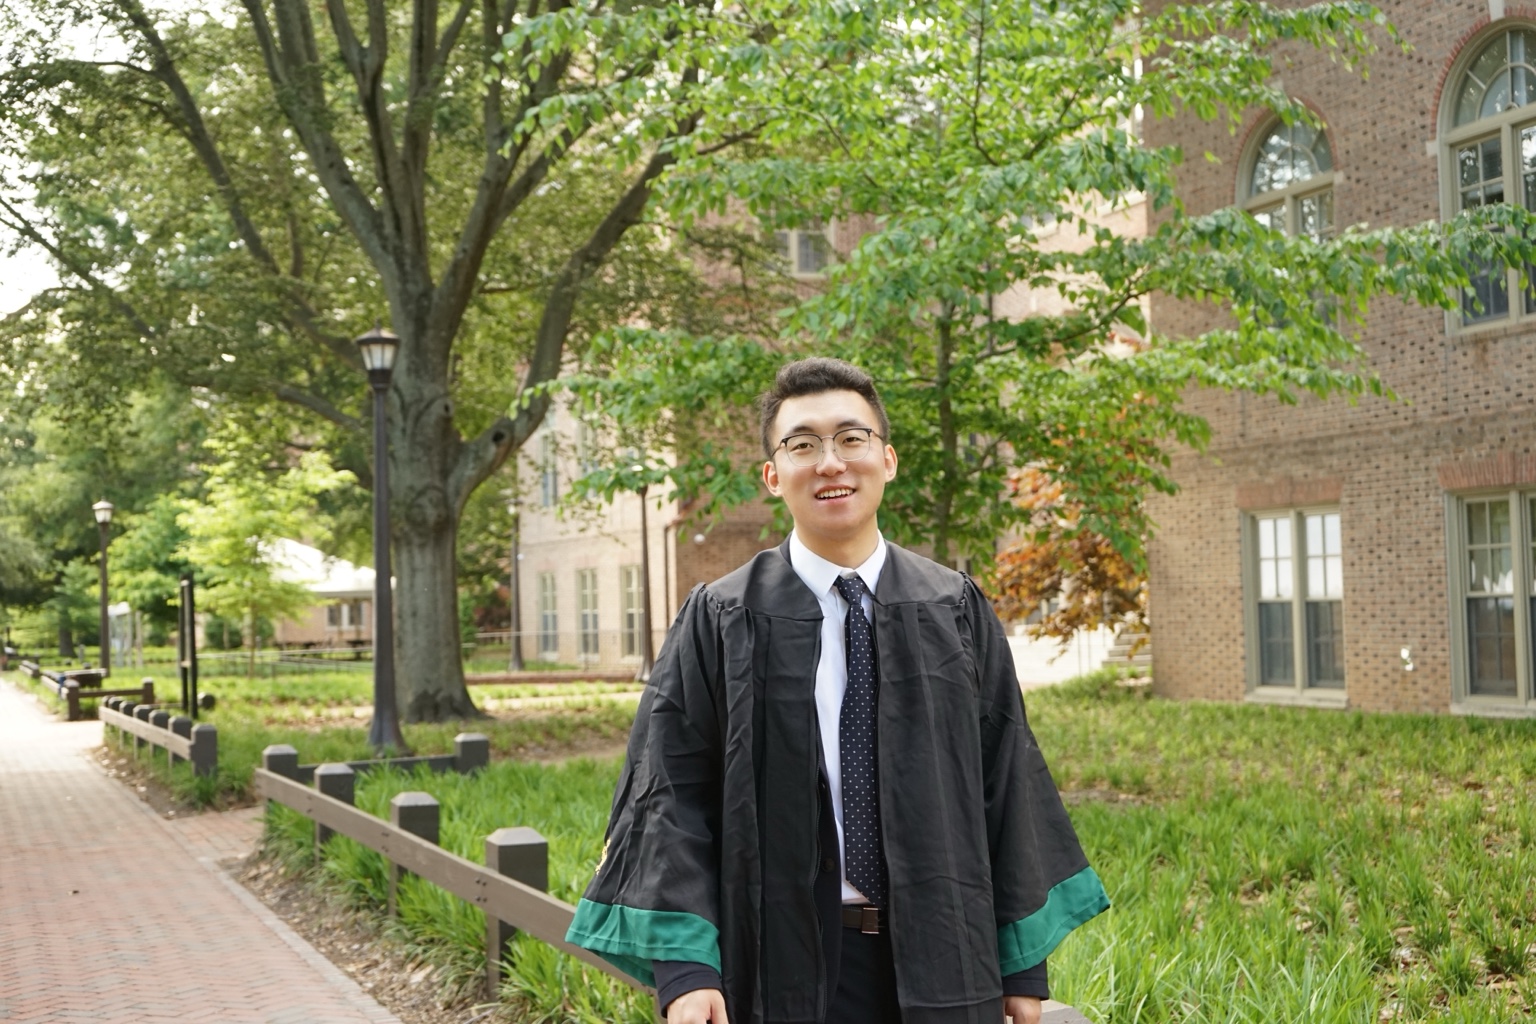
In 2022, I received a B.Sc. in Mathematics and Physics from William & Mary, where I conducted undergraduate research in theoretical physics.
Outside research, I enjoy playing soccer, skiing, reading, and video games.
News
-
Our work on Safe Score Matching (SSM) has been accepted to NeurIPS 2026. The paper and code are now available.
-
I gave an invited talk, Beyond Safety: Reach, Avoid, and Stabilize via Hamilton–Jacobi Reachability, at Seoul National University (SNU). Video
-
Our paper, Solving Reach- and Stabilize-Avoid Problems Using Discounted Reachability, has been accepted to IEEE Transactions on Automatic Control.
Preprints
* Equal contribution
-
-
A Forward Reachability Perspective on Control Barrier Functions and Discount Factors in Reachability Analysis
Automatica, 2026 Conditionally accepted
Publications
-
Safe Score Matching: Diffusion Policies with Hamilton-Jacobi Reachability for Online Safe Reinforcement Learning
Advances in Neural Information Processing Systems, 2026 Accepted
-
Solving Reach- and Stabilize-Avoid Problems Using Discounted Reachability
IEEE Transactions on Automatic Control, 2026 Early Access
-
How Does the Lagrangian Guide Safe Reinforcement Learning through Diffusion Models?
International Conference on Machine Learning, 2026
-
Reach-Avoid-Stabilize Using Admissible Control Sets
IEEE Conference on Decision and Control, 2025
-
Safe Returning FaSTrack With Robust Control Lyapunov-Value Functions
IEEE Control Systems Letters, 8:1373–1378, 2024